ACQUIRE / CONVERT / CONTROL
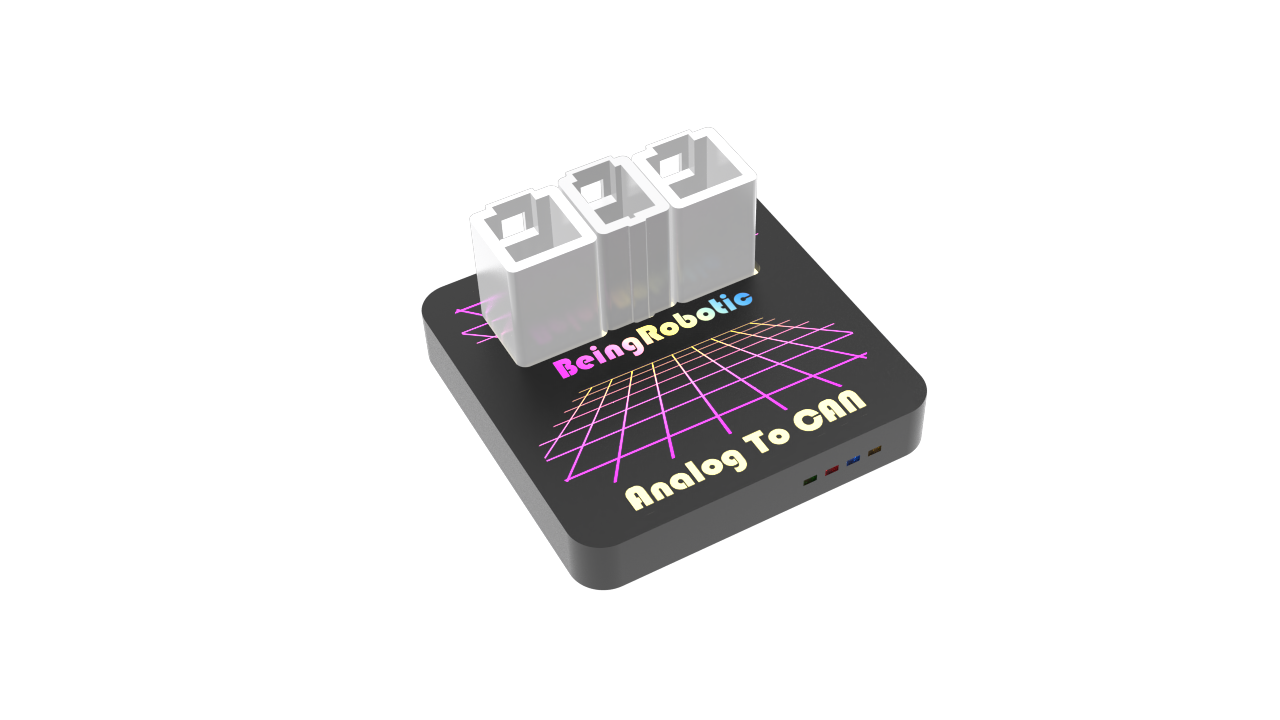
AnalogToCan
Bring analog sensors onto your CAN network, with programmable inputs and PWM outputs for control.
Input ranges: 0–5 V or 0–12 V. Configuration and firmware tailored to your application.
HARDWARE / FIRMWARE / CAN-BUS
Connect sensors. Read the bus. Control your machine.
CAN-bus boards and STM32 firmware, developed together.
THE HARDWARE
Choose the starting point for your application. We take care of the connection between hardware and firmware.

ACQUIRE / CONVERT / CONTROL
Bring analog sensors onto your CAN network, with programmable inputs and PWM outputs for control.
Input ranges: 0–5 V or 0–12 V. Configuration and firmware tailored to your application.
RECORD / ANALYZE / INTEGRATE
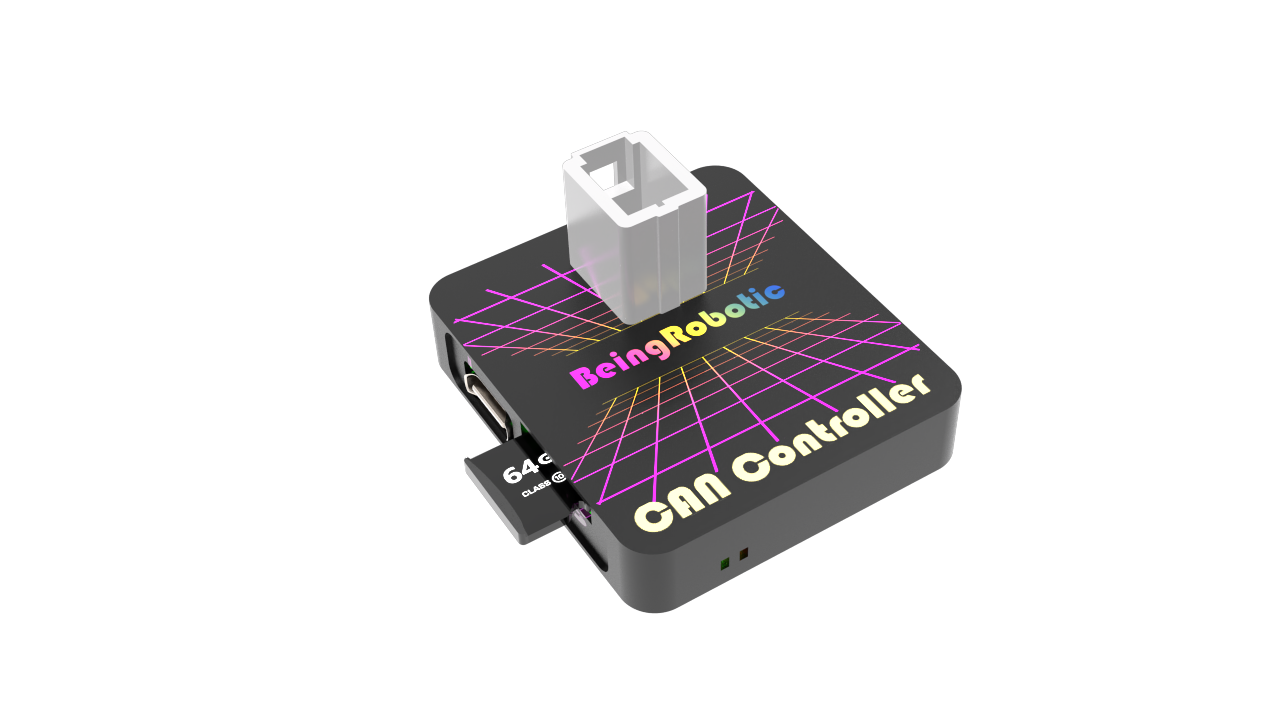
Two independent CAN lines. Record traffic, analyze messages and connect devices that need to work together.
Choose the base board, the wired version or the complete WiFi + RTC configuration.
IN THE FIELD
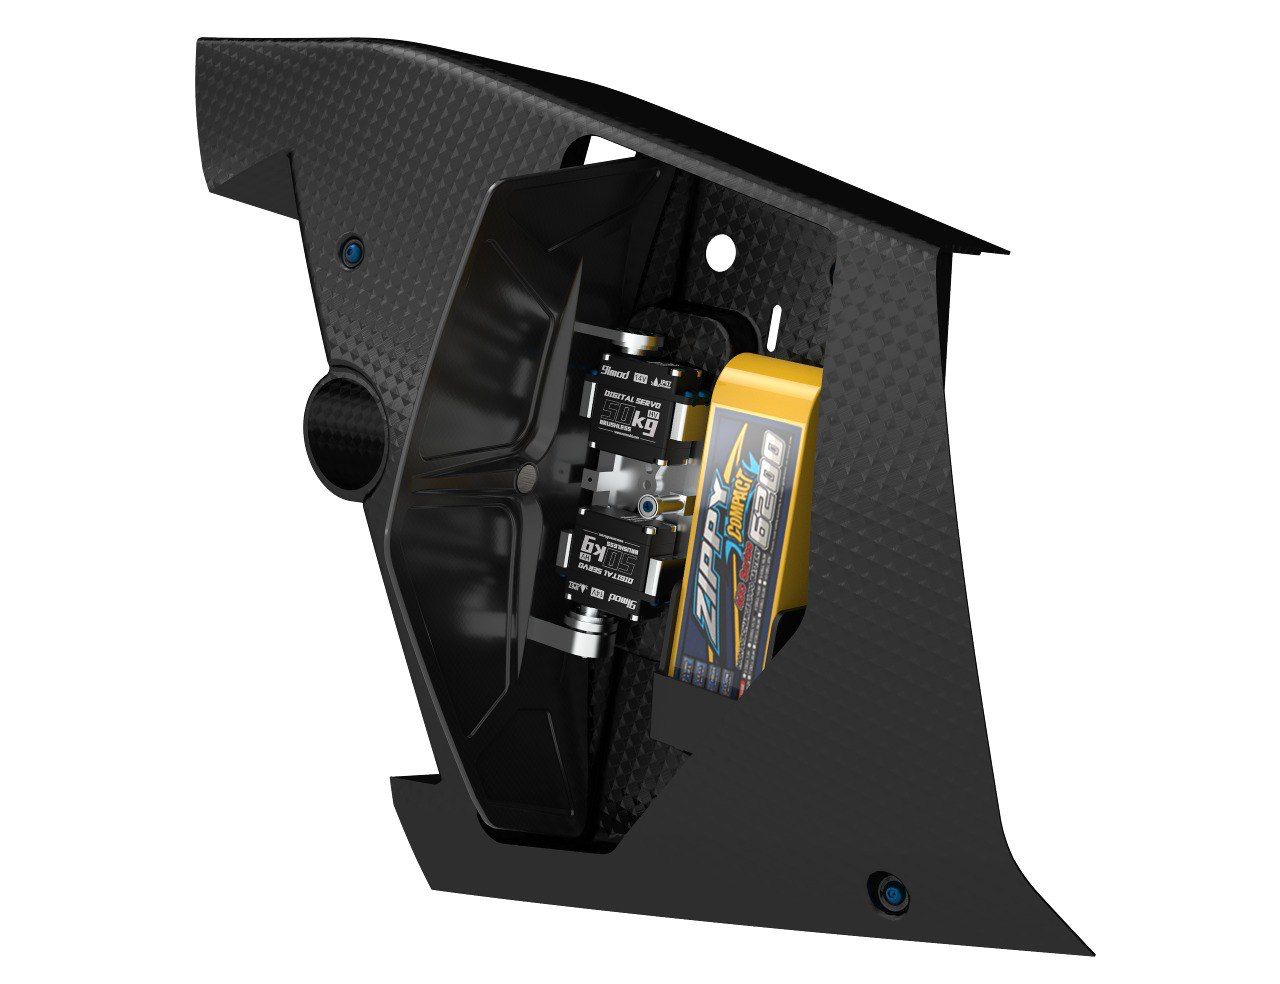
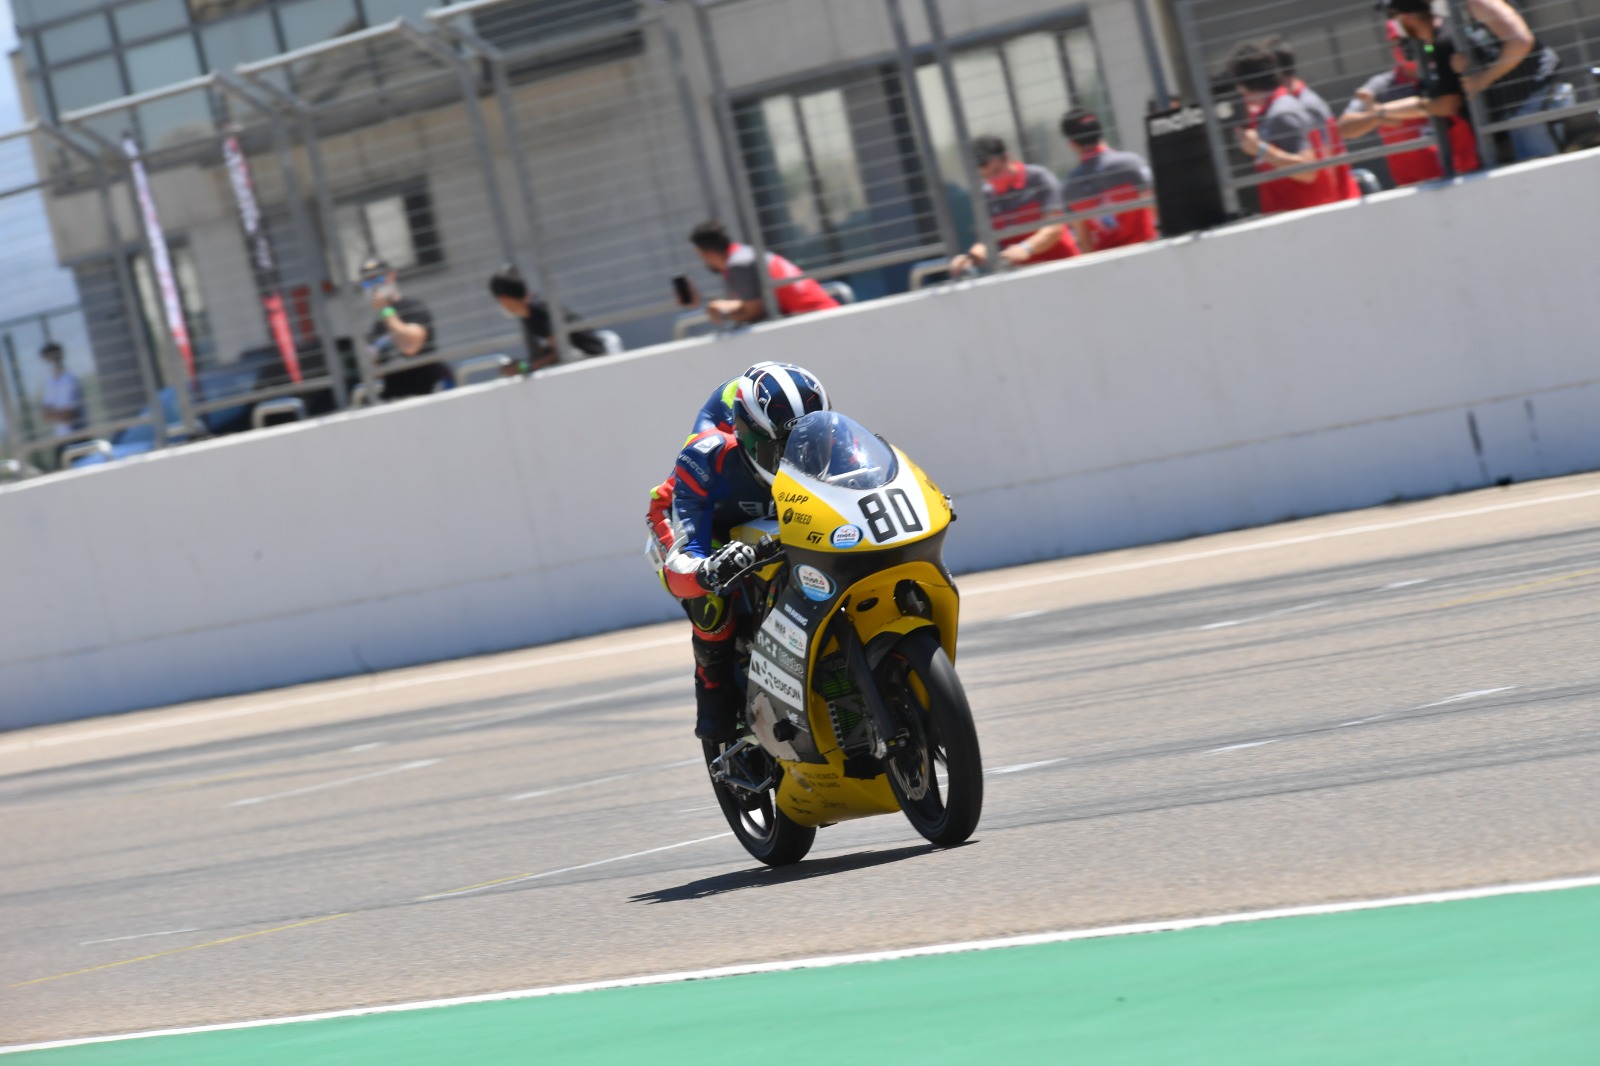
Real vehicles. Real signals. Projects developed with BeingRobotic hardware.
HARDWARE + FIRMWARE
A specific protocol, a different sensor or a new control function. Tell us what your system needs to do: we develop the hardware and STM32 firmware around it.